MIT Engineers Unleash AI-Powered Insect-Scale Flying Robots Capable of Astounding Aerial Agility

In the high-stakes arena of disaster response, every second counts. When catastrophic earthquakes strike, time is measured not just in hours, but in the fragile breaths of survivors trapped beneath pulverized concrete and twisted steel. While search-and-rescue teams traditionally deploy canine units, acoustic listening devices, and heavy machinery, these methods often fail to penetrate the tight, labyrinthine voids of collapsed structures. Larger aerial drones, while useful in open skies, are grounded by their bulk, unable to navigate the claustrophobic spaces where trapped victims await help.
Enter a new frontier in micro-robotics. For years, engineers have dreamed of deploying swarms of tiny, insect-sized flying robots that could buzz through narrow gaps, skirt around falling debris, and peer into the darkest crevices of disaster zones. Yet, until recently, this vision remained largely out of reach. While real insects effortlessly perform dizzying aerial acrobatics, dodging raindrops and executing lightning-fast evasive maneuvers, their artificial counterparts have historically been sluggish, fragile, and bound to painfully simple flight paths.
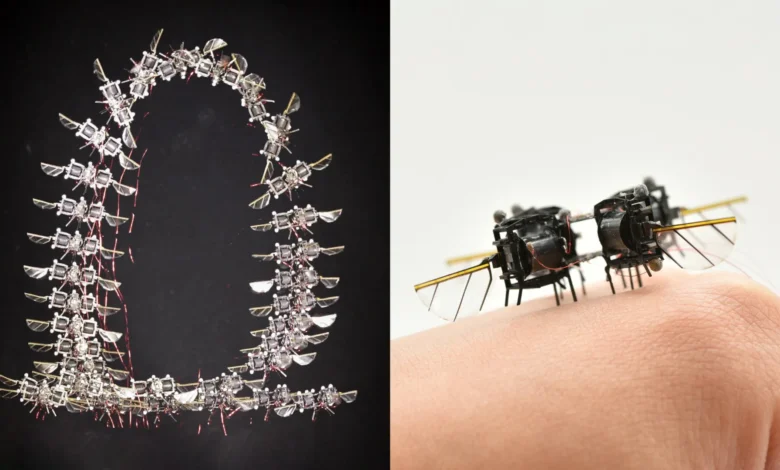
That paradigm is now shifting dramatically. In a breakthrough published in the journal Science Advances, a multidisciplinary team of researchers at the Massachusetts Institute of Technology (MIT) has successfully developed an advanced, artificial intelligence-driven control system. This innovation grants an insect-scale flying robot unprecedented speed, agility, and precision, closing the performance gap between human engineering and nature’s most nimble flyers. By marrying cutting-edge hardware with a sophisticated, two-part computational framework, the MIT team has pushed robotic speed up by roughly 450 percent and acceleration by 250 percent, transforming a sluggish prototype into a high-speed aerial acrobat capable of executing ten consecutive somersaults in just eleven seconds.
The Evolution of Micro-Robotics: Overcoming Hardware and Software Hurdles
The journey toward creating a viable robotic insect has been arduous, spanning over five years of intensive research within MIT’s Soft and Micro Robotics Laboratory. Led by Kevin Chen, an associate professor in the Department of Electrical Engineering and Computer Science (EECS) and head of the laboratory within the Research Laboratory of Electronics (RLE), the team initially focused on solving the fundamental physical limitations of micro-flight.
Previously, these tiny machines—roughly the size of a microcassette tape and weighing less than a single paperclip—suffered from fragile designs and weak actuators. Chen’s laboratory recently achieved a major hardware milestone by developing a much more durable version of the robot. This updated architecture features larger, highly resilient flapping wings driven by novel soft artificial muscles. These artificial muscles contract at extraordinary speeds, mimicking the rapid wingbeats of natural insects and generating the raw thrust required for aggressive flight maneuvers.
However, resolving the physical hardware was only half the battle. The true bottleneck lay in the robot’s "brain"—its flight controller. Operating a lightweight aerial vehicle in real time presents immense aerodynamic challenges. The physics governing micro-scale flight are notoriously complex, subject to rapid air disturbances, wind gusts, and unpredictable micro-turbulences that can easily destabilize a sub-gram machine.
In earlier iterations, human engineers had to manually tune the controller to maintain stable hover or basic forward motion. To execute the high-speed, aggressive maneuvers seen in natural insects, the robot required a control system capable of navigating extreme uncertainty while solving complex mathematical equations instantaneously. Ordinarily, a controller powerful enough to manage these demands would require massive computational resources—far too heavy for a tiny robot to carry onboard, and too slow to process data in real time.
The Two-Tiered AI Breakthrough
To circumvent this computational bottleneck, Chen’s team joined forces with the laboratory of Jonathan P. How, the Ford Professor of Engineering in the Department of Aeronautics and Astronautics and a principal investigator in the Laboratory for Information and Decision Systems (LIDS). Together, the researchers engineered a novel, two-part control architecture that cleverly balances high-level computational planning with real-time operational efficiency.
The first tier of this system relies on a model-predictive controller. This advanced mathematical model evaluates the robot’s physical dynamics in real time, predicting its future behavior and calculating the optimal sequence of actions to safely navigate a desired flight path. While this expert planner demands substantial computational power—offloaded to external systems during testing—it possesses the sophistication needed to map out complex, high-stress maneuvers such as sharp turns, aggressive body-angle pitching, and aerial flips. Furthermore, the planner factors in the strict physical limitations of the robot’s actuators, preventing commands that would exceed torque or force thresholds and result in a crash.
Mastering repeated aerial flips, in particular, proved to be an extraordinary technical challenge. Executing a single somersault requires precise timing, but stringing multiple flips together demands that the robot instantly correct micro-errors at the completion of each rotation. If tiny deviations are allowed to compound, the robot’s trajectory deteriorates rapidly, leading to a catastrophic loss of control.
To solve this, the researchers bridged the gap between heavy computation and real-time execution using imitation learning. They fed the data generated by the expert model into a deep-learning network, training a streamlined policy to replicate the expert planner’s decision-making process. This resulting AI policy serves as the robot’s real-time brain, translating incoming positional data into instantaneous commands for thrust force and torque. By distilling complex calculations into a lightweight AI model, the system can operate with the speed necessary for high-frequency flight control without weighing down the machine.
Quantifying Agility: Record-Breaking Performance Metrics
The implementation of this two-step control framework yielded immediate, staggering results in laboratory experiments. When subjected to rigorous testing inside MIT’s motion-capture facilities, the insect-scale robot shattered previous benchmarks.
Comparative data released by the research team highlights the dramatic performance leap:
- Speed Increase: The robot achieved a 447 percent increase in forward velocity compared to previous control frameworks.
- Acceleration Gains: Acceleration capacity surged by approximately 255 percent.
- Flight Precision: During stress-testing, the robot successfully completed 10 consecutive somersaults in a mere 11 seconds, all while maintaining a tight trajectory within just 4 to 5 centimeters of its intended flight path—even when subjected to artificial wind disturbances designed to knock it off course.
In addition to continuous backflips, the team demonstrated a specialized insect maneuver known as a saccade. In the natural world, insects use saccades to pitch their bodies sharply, rapidly transition to a new location, and then counter-pitch to brake instantly. This rapid acceleration and deceleration not only aids in spatial navigation but also stabilizes the insect’s visual field. Mastering this capability is a critical stepping stone for future applications where these robots will be expected to carry optical sensors and cameras.
Global Implications and the Future of Autonomous Micro-Robotics
While the immediate applications of this technology in search-and-rescue operations capture the imagination, the broader implications of MIT’s research extend deep into military reconnaissance, environmental monitoring, and industrial infrastructure inspection.
Traditional quadcopter drones, while remarkably capable, are fundamentally limited by their scale. They pose safety hazards when flown in close proximity to humans, require significant airspace, and are easily blocked by narrow entry points. Insect-scale robots, by contrast, open up entirely new dimensions of multimodal locomotion. They can operate in confined spaces previously deemed inaccessible to autonomous machinery—ranging from the interior cavities of heavy industrial machinery and aircraft engines to collapsed tunnels and rubble heaps following natural disasters.
Despite these promising strides, significant technical hurdles remain before these micro-robots can be deployed in real-world disaster zones. Currently, the experimental robots rely on an external motion-capture camera system to determine their precise location in space. For these machines to achieve true autonomy, engineers must miniaturize and integrate sensors and cameras directly onto the robot’s chassis, allowing them to navigate complex, GPS-denied environments entirely on their own.
Looking ahead, the research team is actively exploring onboard sensing technologies. Future phases of the project will investigate whether lightweight sensors can facilitate peer-to-peer communication between swarms of robotic insects. This would enable them to coordinate their movements collectively, avoid mid-air collisions, and systematically map expansive, hazardous areas without human intervention.
As Kevin Chen emphasized, the success of this bio-inspired framework signals a vital paradigm shift for the micro-robotics community. By proving that advanced control algorithms can unlock high-performance agility in soft, lightweight machines, MIT has laid the foundational architecture for the next generation of autonomous flying systems.
The research was supported by financial backing from key federal and academic institutions, including the National Science Foundation (NSF), the Office of Naval Research, the Air Force Office of Scientific Research, MathWorks, and the Zakhartchenko Fellowship. As development continues to accelerate, the day when tiny robotic insects rush into disaster zones to save human lives draws steadily closer from science fiction into scientific reality.